Robotics

In orbit

KIBO Robot Programming Challenge

JAXA, Japan · Team Enigma Systems · STEMX365 · 2021 and 2022

Play the video
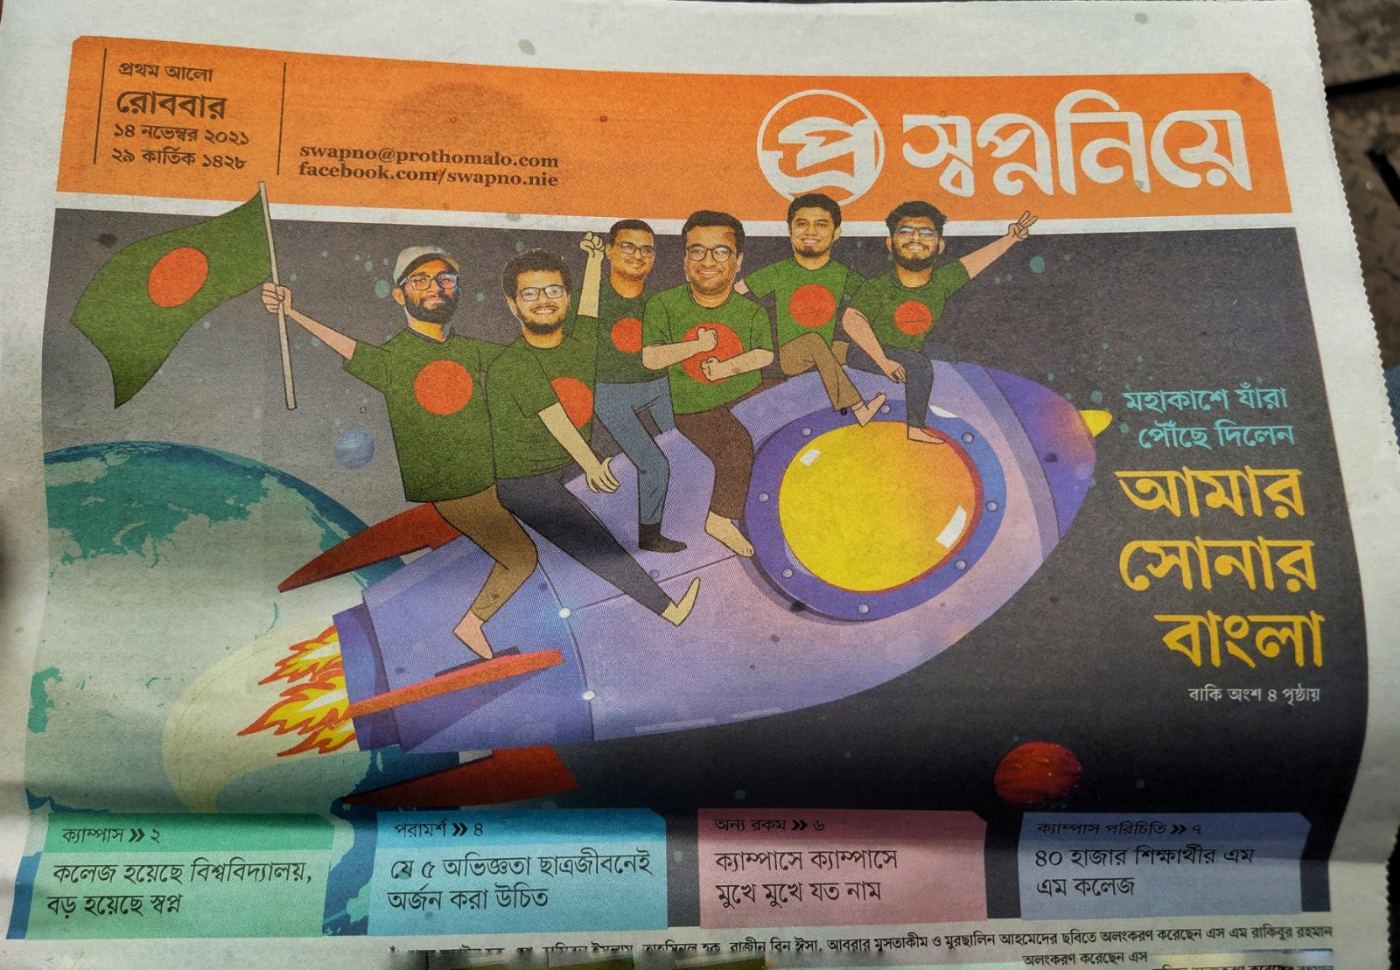
Team Enigma Systems illustrated on the cover of Prothom Alo's Swapno Niye, 14 November 2021 Photo coming soon
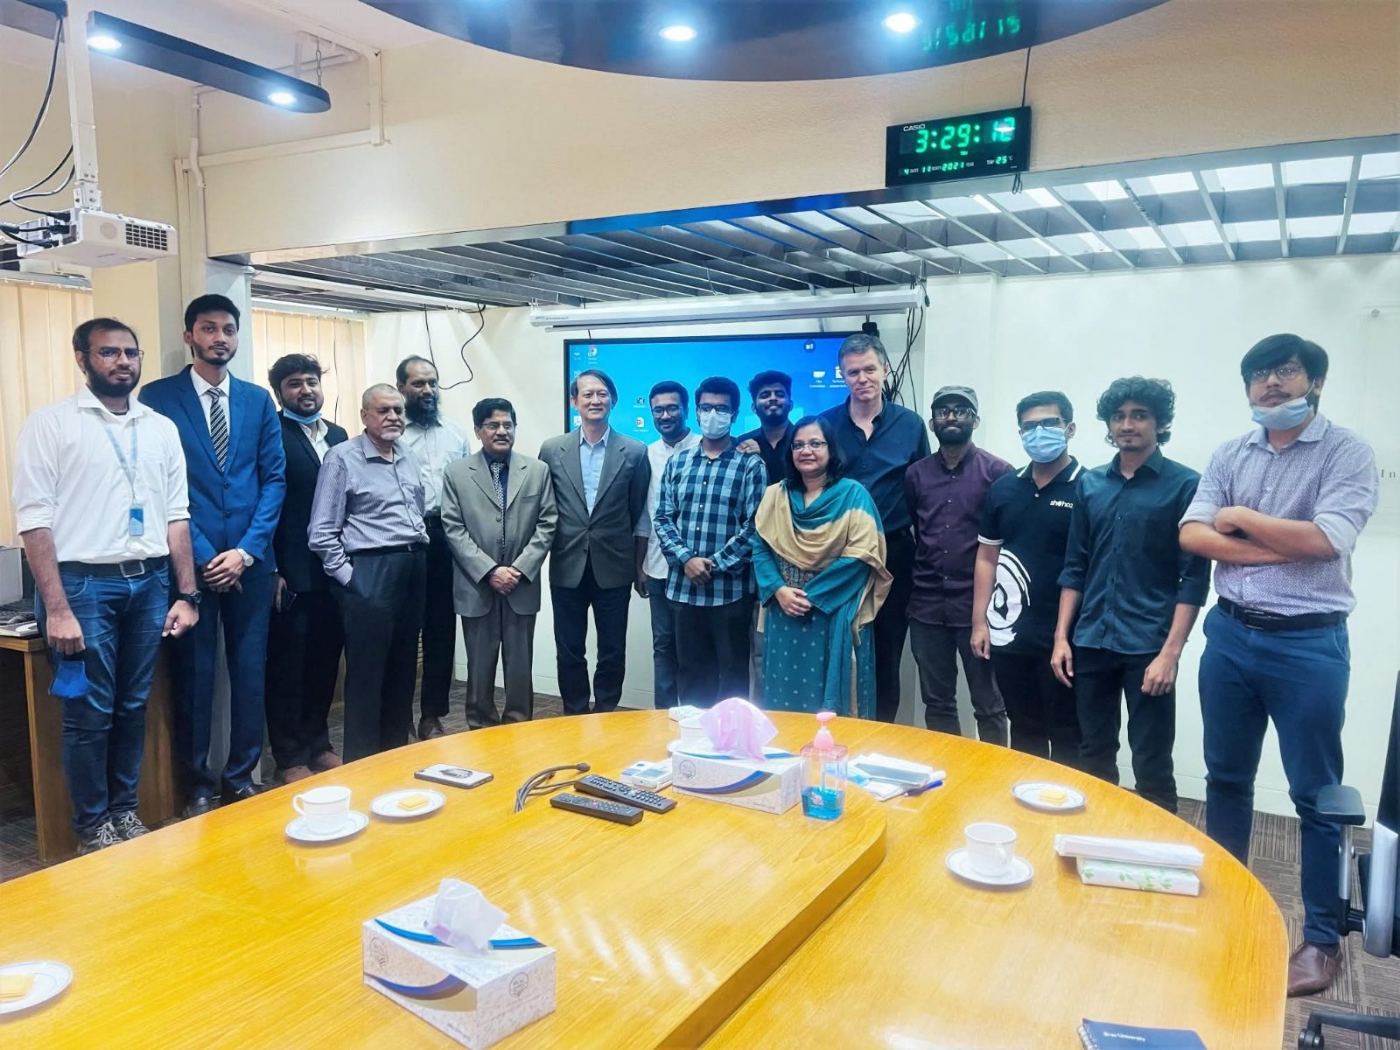
Team Enigma Systems in a group photo, 4 November 2021 Photo coming soon

2021

Runner-up, KIBO Robot Programming Challenge

Final round held aboard the International Space Station

The first team from Bangladesh to upload a computer program to the International Space Station. It flew NASA's Astrobee free-flying robot inside JAXA's Kibo module.

I built the control and navigation software in Java, with real-time pose estimation from QR and AR tags using OpenCV-Contrib, tested in ROS and RViz.

  • 1st in the national round
  • 3rd in the international programming skills round
  • Crew Award
View the Astrobee project
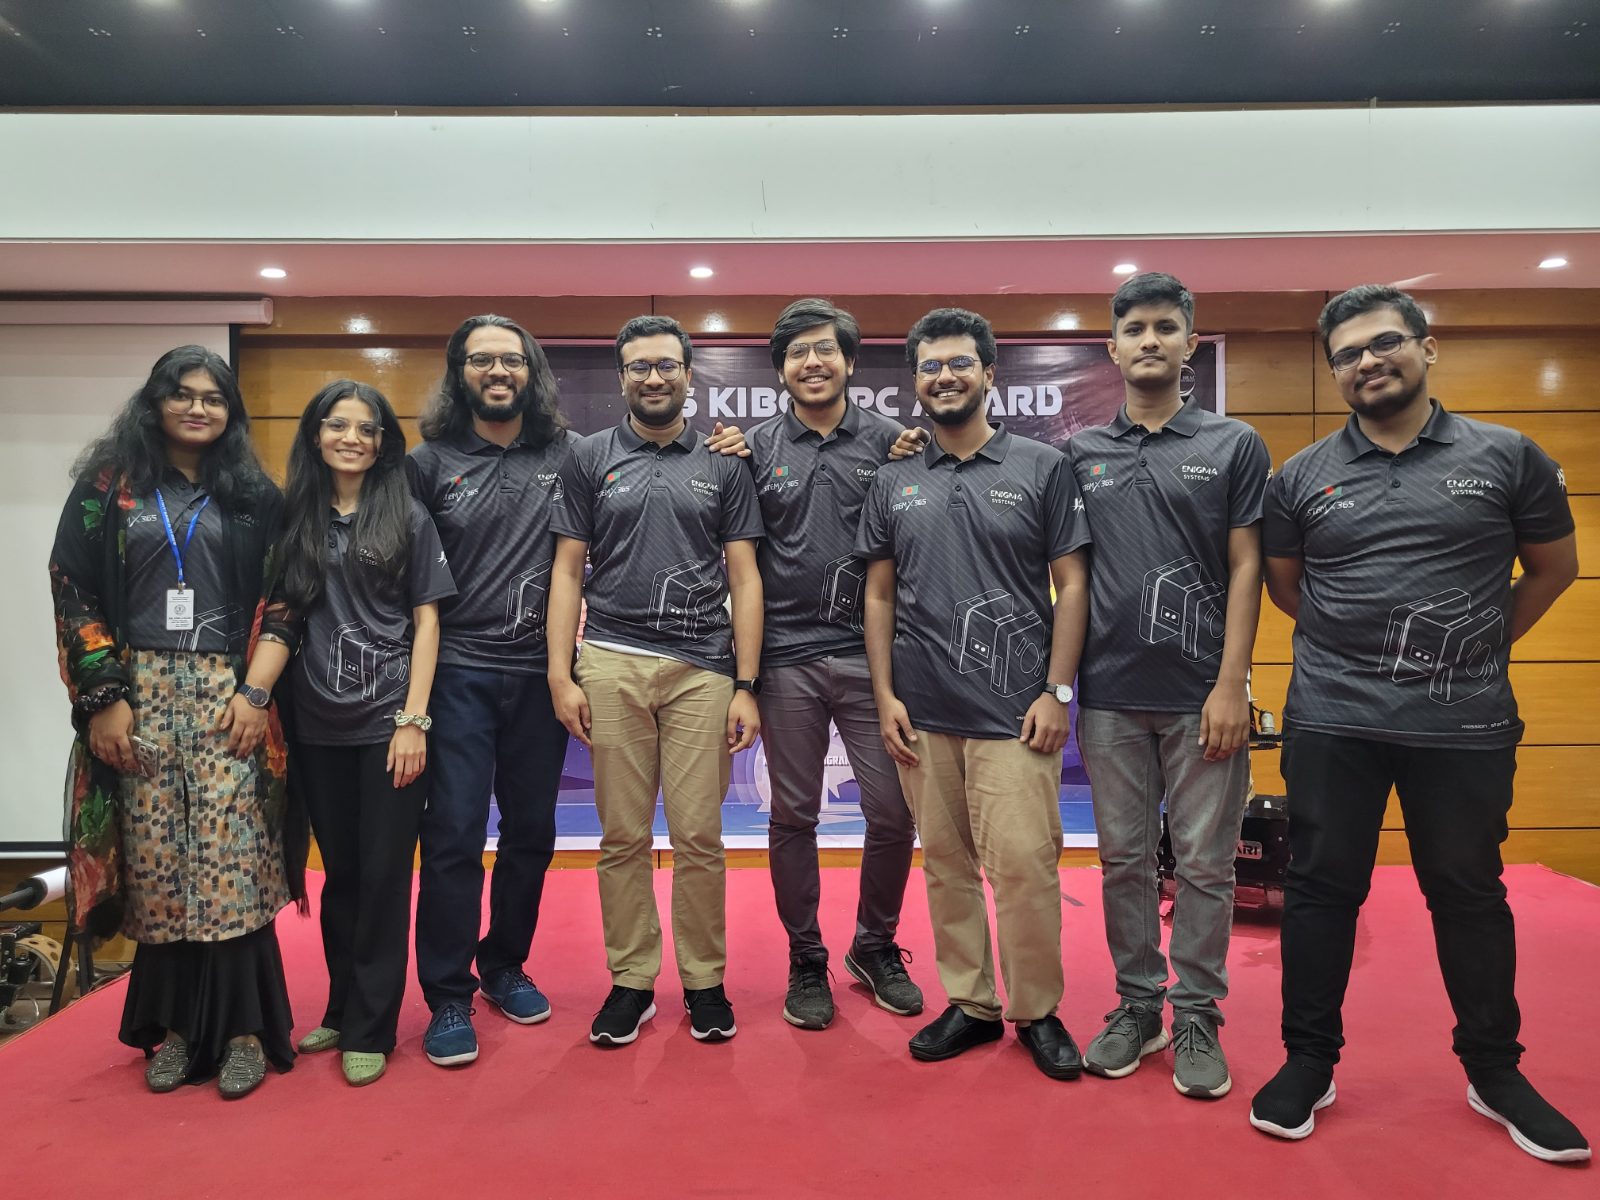
Team Enigma Systems on stage at the KIBO RPC award ceremony, August 2022 Photo coming soon

2022

Back on the ISS, Crew Award again

KIBO RPC, JAXA · Team Enigma Systems · STEMX365

Won the national round again, and our program ran on Astrobee aboard the ISS for the second year in a row.

2025

Passing it on

STEMX365

Wrote the reference Astrobee skeleton code for KIBO RPC 6 teams.

View on GitHub
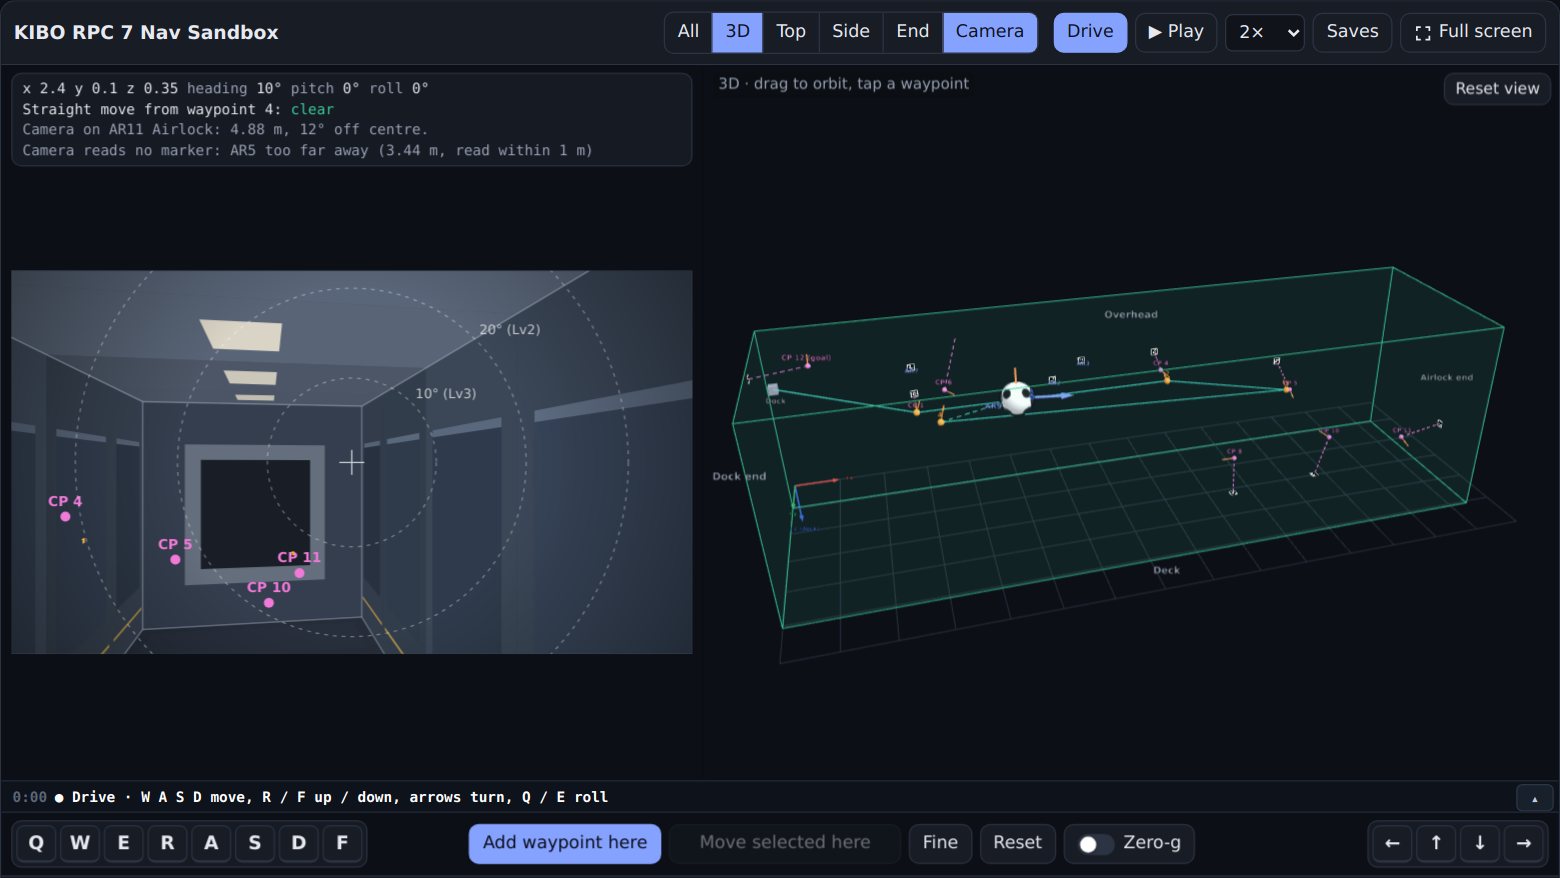
The KIBO RPC 7 Nav Sandbox in Drive mode: the robot camera looking down the Kibo module on the left, and a 3D view of the module, the robot and its route on the right Photo coming soon

2026

KIBO RPC 7 Nav Sandbox

Open source · runs in the browser

A practice ground for KIBO RPC 7 teams: plan Astrobee routes through the Kibo module, check them against the keep-in and keep-out zones, see which AR markers the robot camera reads, and fly the robot by hand, with a zero-gravity mode.

Open the sandbox

Rovers for Mars

BRACU Mongol Tori

BRAC University's Mars rover team · Sub-team lead · 2019 to 2021

Play the video
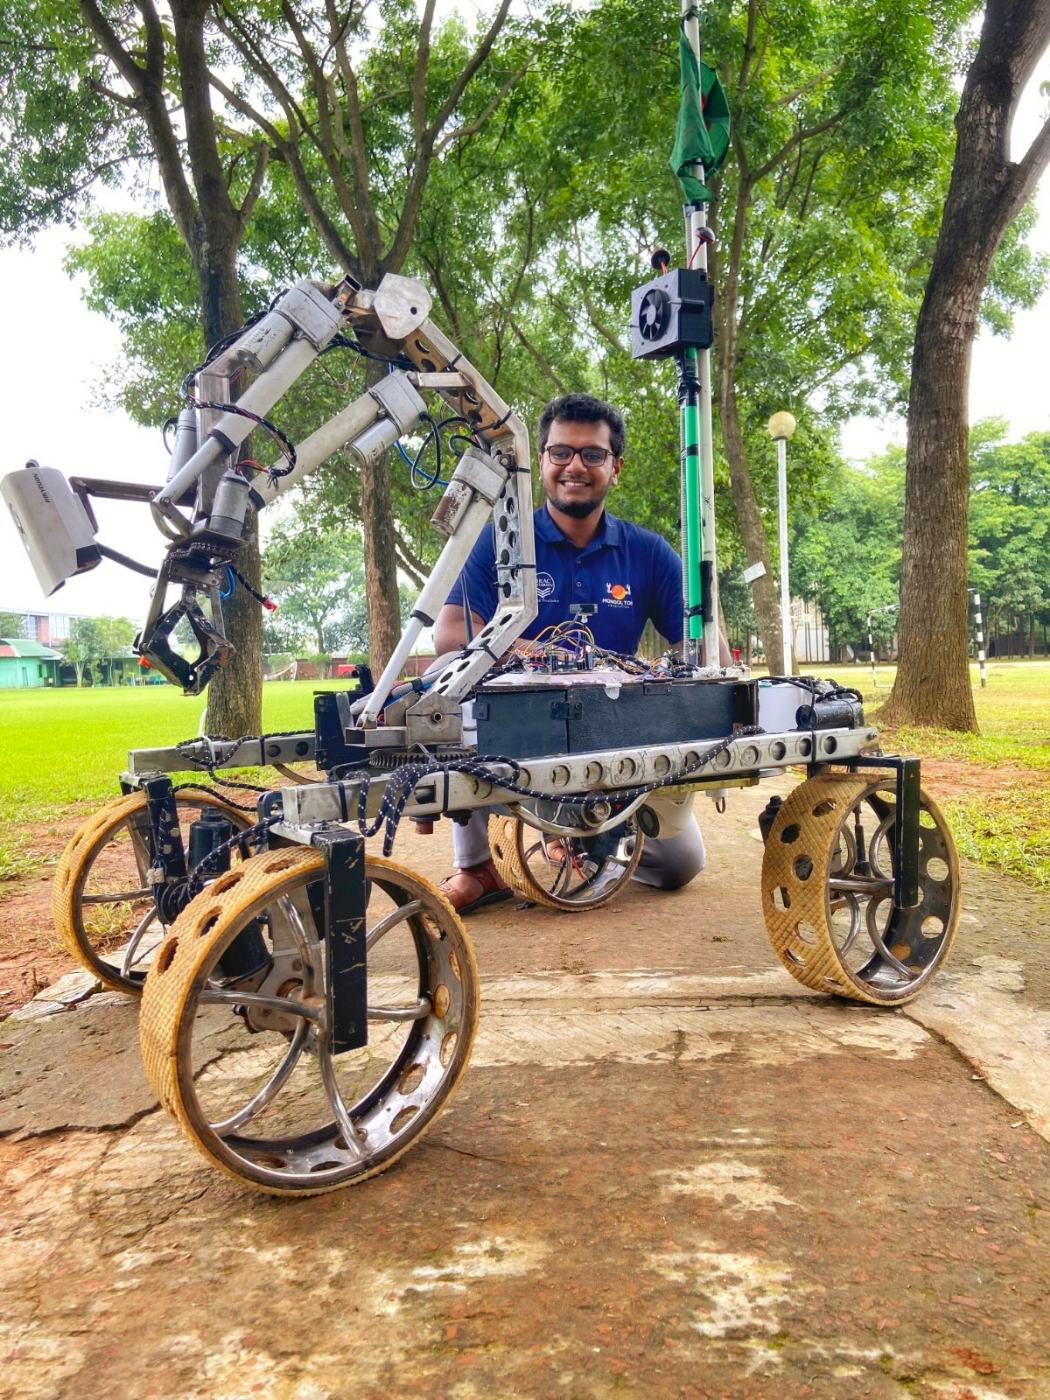
The BRACU Mongol Tori Mars rover and its robotic arm Photo coming soon
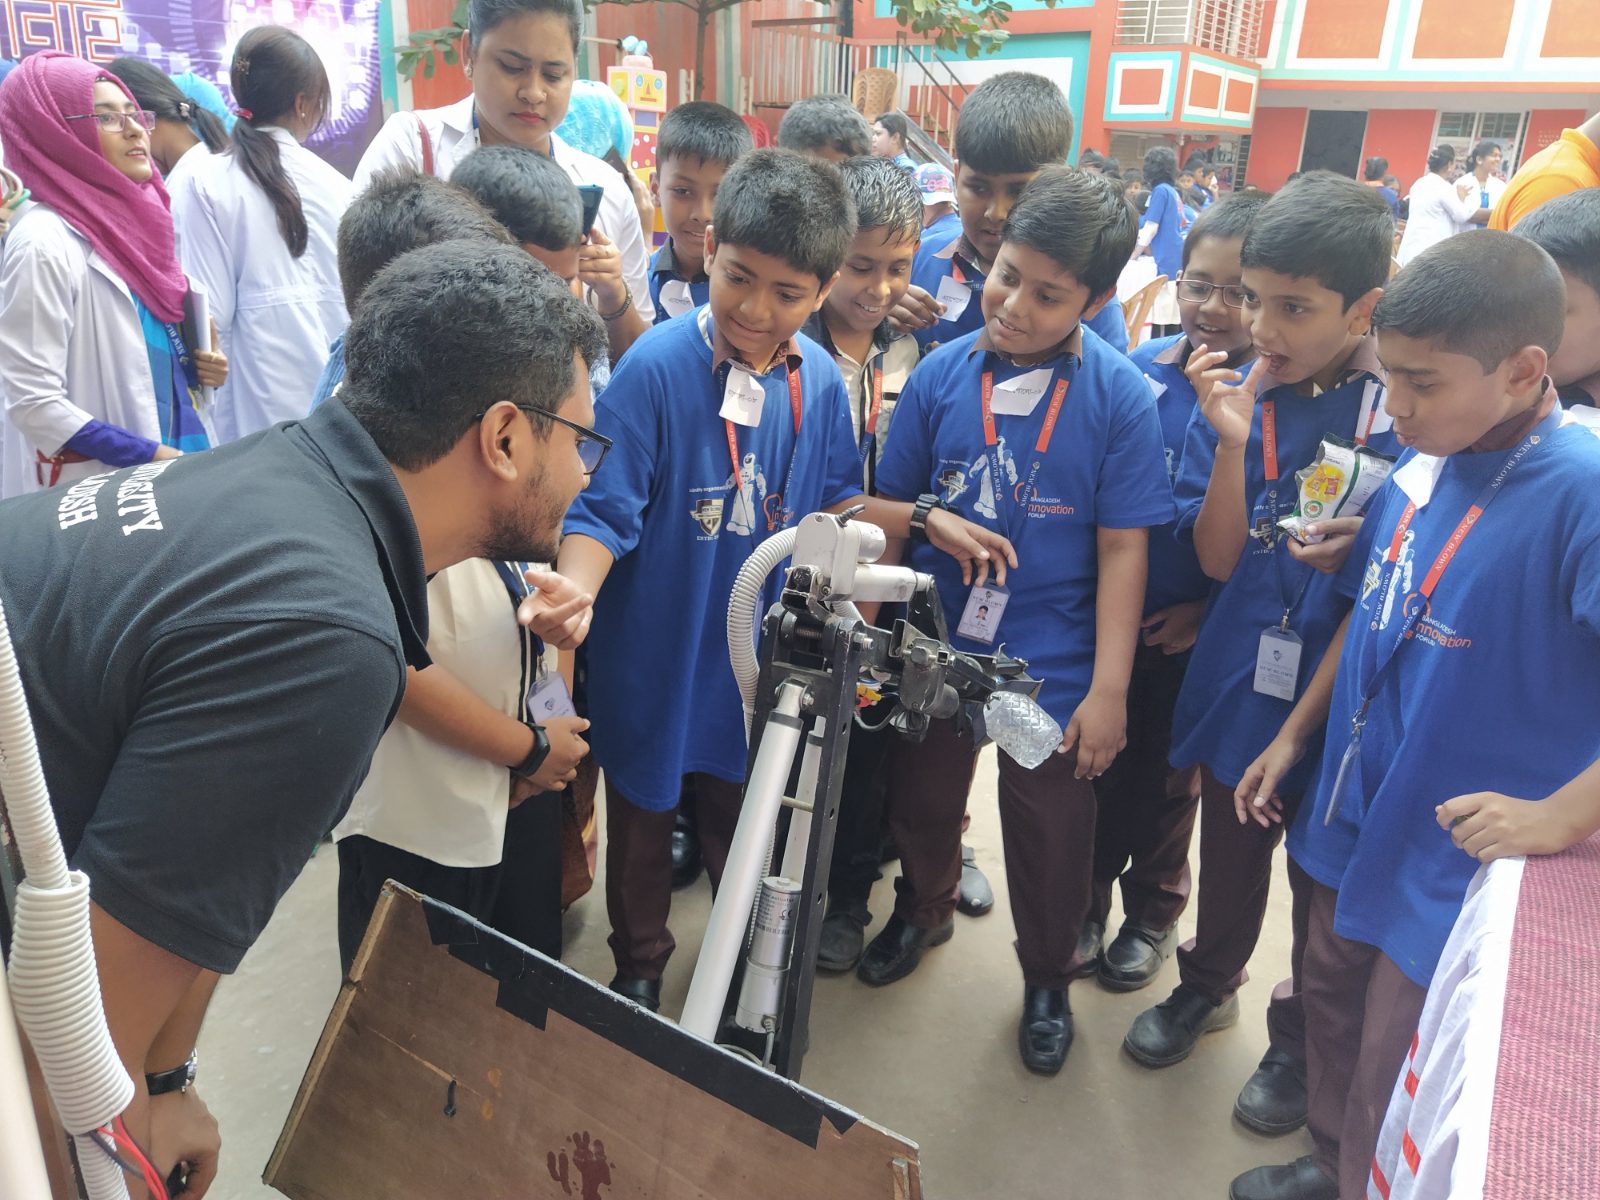
Demonstrating the Mongol Tori robotic arm to school students at an innovation fair, November 2019 Photo coming soon

The rover's systems backbone

Software, radio links, cameras and the base station

Mongol Tori designs and builds a Mars rover prototype that competes against university teams from around the world, driving rough terrain, operating a robotic arm and running science tasks far from its operators. I orchestrated the backbone that ties it together: the software that drives the rover and the links that connect it to the people operating it.

  • First on the rover ROS: I taught myself ROS during the COVID break and brought it to Mongol Tori for the first time as the rover's control stack, alongside a Python socket-based control system and inverse kinematics with Gazebo simulation for the 6-DOF arm.
  • Long-range link: Ubiquiti Rocket M2 radios with sector antennas and Bullet M2 radios with omni antennas.
  • Cameras: analog 5.8 GHz FPV and digital IP cameras placed around the rover for remote operation.
  • Base station: the network for controlling and monitoring the rover.
View the arm simulation

Results

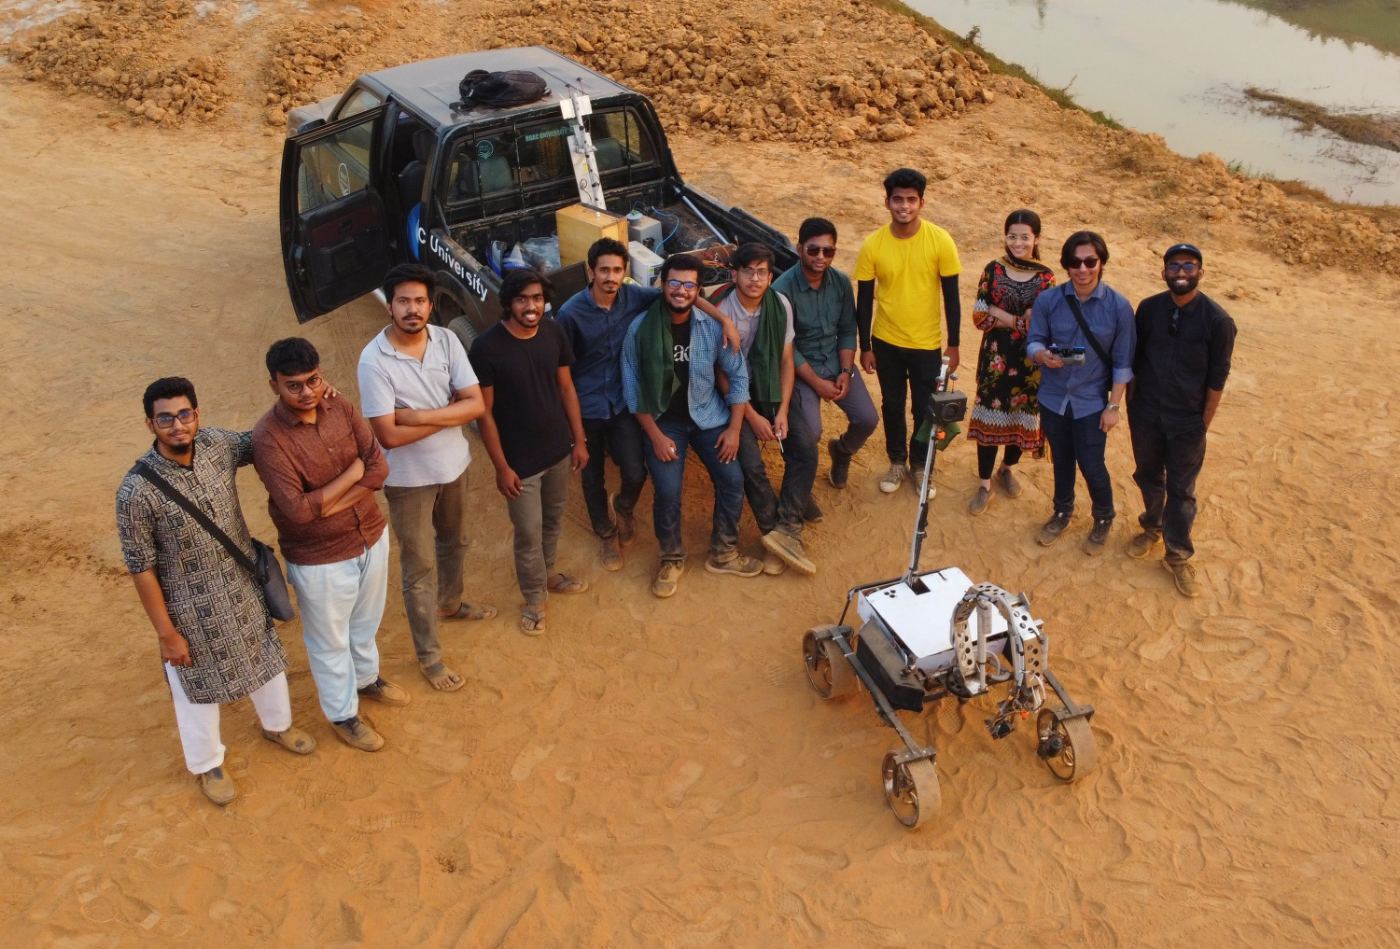
  1. Aerial photo of the BRACU Mongol Tori team with the rover, University Rover Challenge 2020 season Photo coming soon
    3rd University Rover Challenge 2020The Mars Society, USA. Judged on the System Acceptance Review during the pandemic
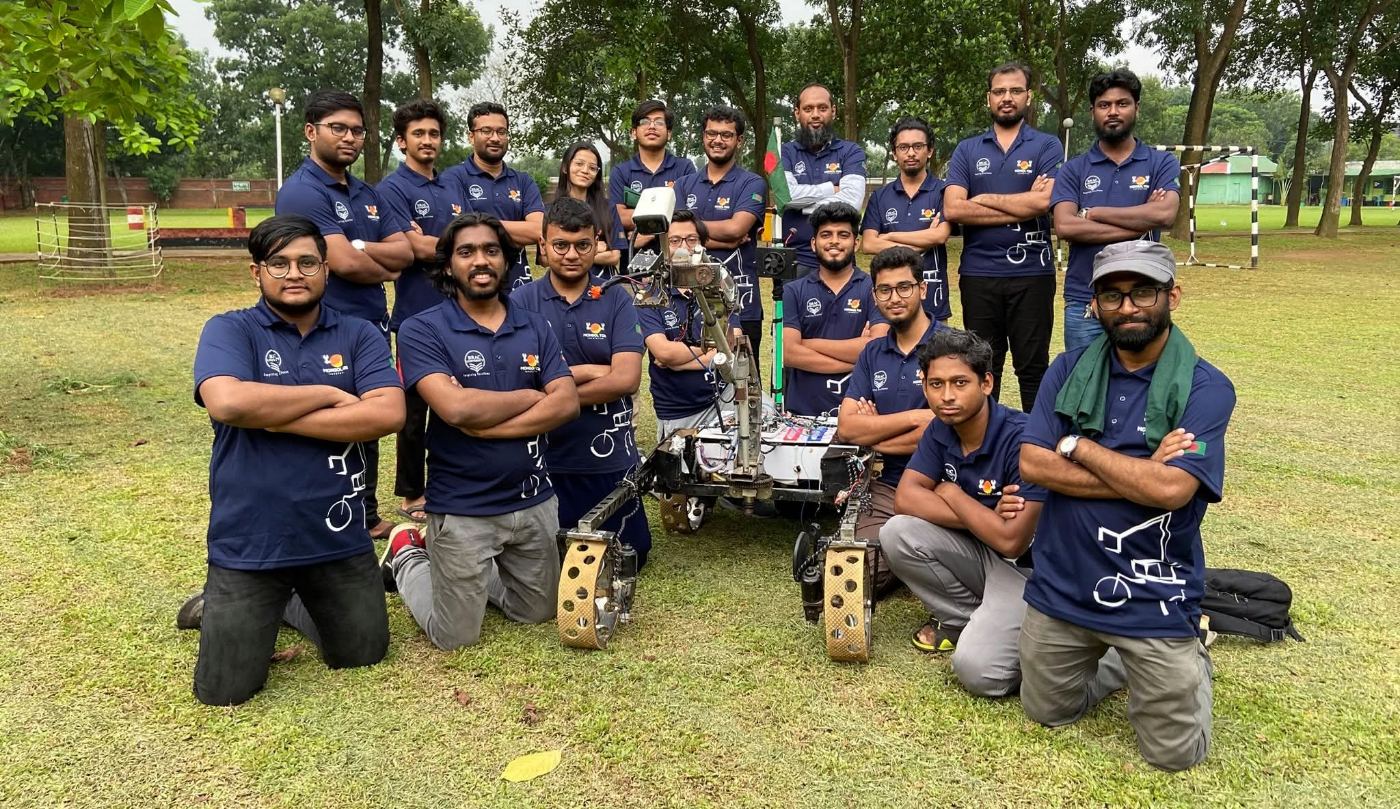
  2. The BRACU Mongol Tori team with the rover, University Rover Challenge 2021 season Photo coming soon
    4th University Rover Challenge 2021The Mars Society, USA
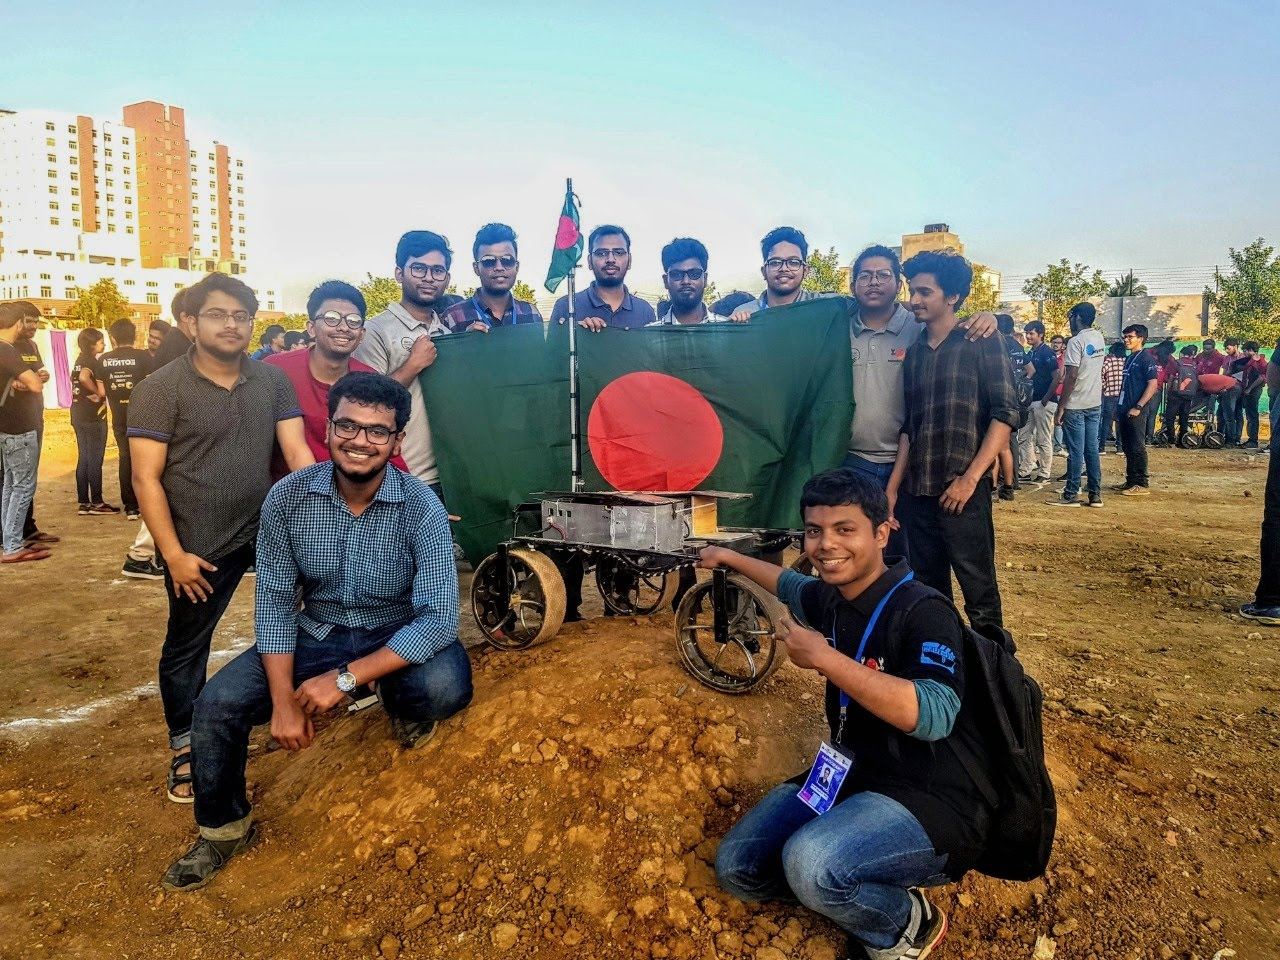
  3. The BRACU Mongol Tori team with the rover and the Bangladesh flag at the Indian Rover Challenge 2020 Photo coming soon
    7th Indian Rover Challenge 2020Out of 21 teams from around the world

On my bench

Robots I built myself

From a PID line follower to a 6-DOF arm with a simulated twin

6-DOF robotic arm

2020 to 2021

Inverse kinematics for a six-joint arm, with a ROS and Gazebo shadow that mirrors the arm in simulation.

View the simulation

PID line-following robot

2017 to 2018

A line-following robot steered by a PID controller that keeps it centred on the track.

Self-balancing robot

Own build

A two-wheeled robot that keeps itself upright with closed-loop control.